MULTI-FINGERED HAND
Dexterity, power, and durability.
The only hand realized at human scale.
TECHNOLOGY
Technologies behind the multi-fingered hand
TECHNOLOGY / Details
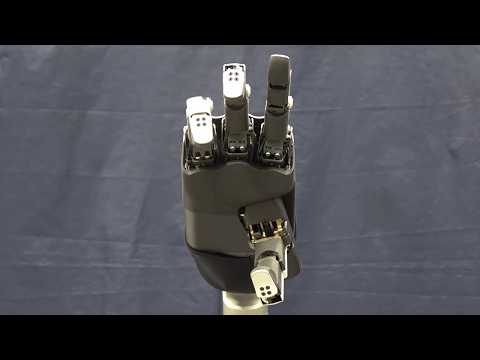
Dexterity
16 DOF / 180 deg/s16 active joints / Finger-thumb opposability / Maximum joint velocity 180 deg/sec
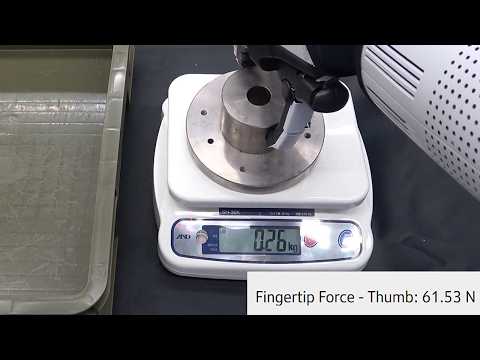
Power
50N / 150sIt can exert a maximum fingertip force of 50 N and sustain it for up to 150 seconds.
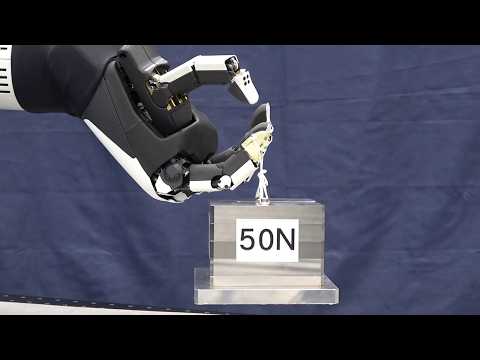
Durability
450,000+ cyclesIt has completed 450,000 durability cycles under various fingertip load conditions, including 24,000 cycles involving lifting a 5 kg weight.
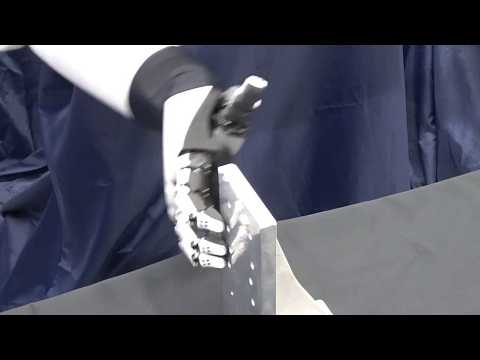
Impact Resistance
1.23m/sEven when the fingers hit an obstacle at 1.23m/s, the system can detect it and switch control mode to absorb the force.
Tactile sensor
288 channelsIn addition to six-axis force sensors at each fingertip, a total of 288 channels of tactile sensors are integrated into the fingers and palm, enabling high-precision contact detection and delicate manipulation.
FEATURES


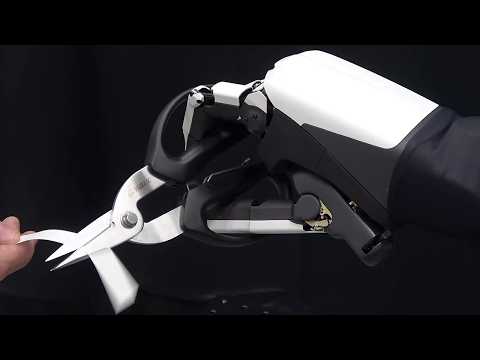
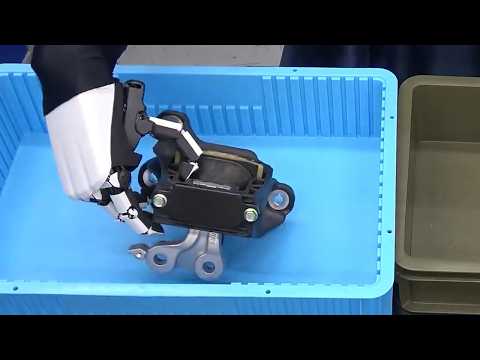
While human hands are both dexterous and powerful, robots have struggled to achieve the same balance. Powered by the proprietary “Willow Drive” actuation system, our multi-fingered hand provides the precision necessary to thread a needle, as well as an output of 50 N at a human scale. We have finally reached a practical level where it can “work like a human.”
WORK SCENES
Work Scenes
Threading a needle
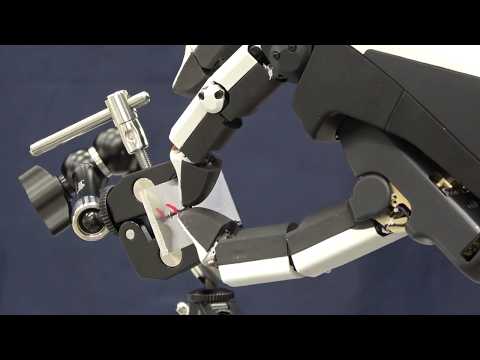
Tightening a small screw
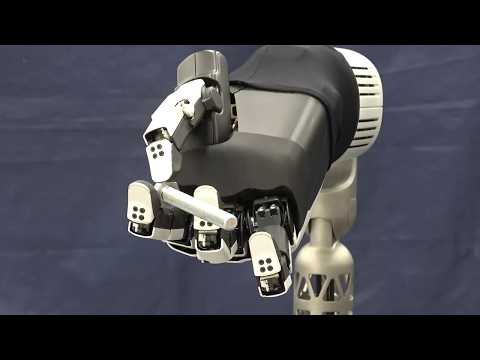
Manipulating a bolt
Using scissors
Overseas research branches
Research and development through a global network
Publications
Published papers on multi-fingered hands